## On this page
# vss::feedback\_control::FlashLidarReceiver Struct Reference
Last update: 16.07.2025
Receiver parameters of the flashing lidar. [More...](a00294.xhtml#details)
Collaboration diagram for vss::feedback_control::FlashLidarReceiver:
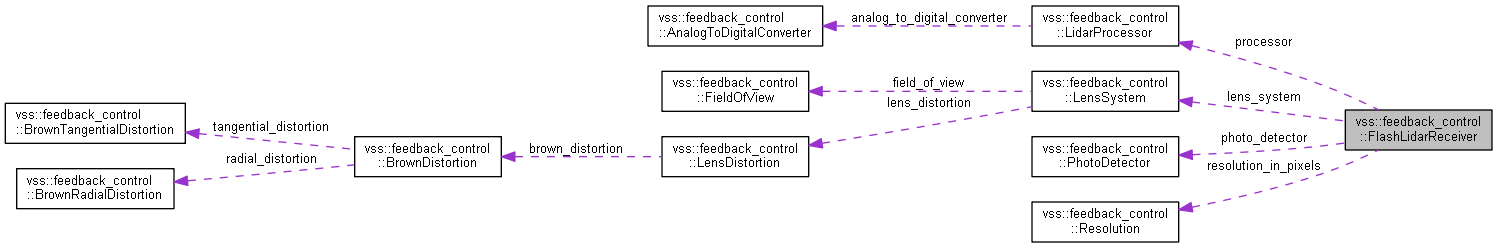
\[[legend](graph_legend.xhtml)\]
## Public Attributes
[LensSystem](a00298.xhtml) [lens\_system](a00294.xhtml#a1d65910e3bdf6f69c22b238e5fbc9299) = 1 [Resolution](a00302.xhtml) [resolution\_in\_pixels](a00294.xhtml#a99f3342a135f634b4553905e2248004e) = 2 [PhotoDetector](a00322.xhtml) [photo\_detector](a00294.xhtml#ab15b5a6299e3b08ebff5eb4d48d0b086) = 3 [LidarProcessor](a00326.xhtml) [processor](a00294.xhtml#ac4b4ff5c509cf093466dfed1bb2b895b) = 4 ## Detailed Description
Receiver parameters of the flashing lidar.
## Member Data Documentation
## [◆ ](#a1d65910e3bdf6f69c22b238e5fbc9299)lens\_system
[LensSystem](a00298.xhtml) vss::feedback\_control::FlashLidarReceiver::lens\_system = 1
`LensSystem`.
## [◆ ](#ab15b5a6299e3b08ebff5eb4d48d0b086)photo\_detector
[PhotoDetector](a00322.xhtml) vss::feedback\_control::FlashLidarReceiver::photo\_detector = 3
`PhotoDetector`.
## [◆ ](#ac4b4ff5c509cf093466dfed1bb2b895b)processor
[LidarProcessor](a00326.xhtml) vss::feedback\_control::FlashLidarReceiver::processor = 4
`LidarProcessor`.
## [◆ ](#a99f3342a135f634b4553905e2248004e)resolution\_in\_pixels
[Resolution](a00302.xhtml) vss::feedback\_control::FlashLidarReceiver::resolution\_in\_pixels = 2
`Resolution`.
---
The documentation for this struct was generated from the following file:- feedback\_control\_lidar\_parameters.proto