## On this page
# vss::feedback\_control::FeedbackControlDescription Struct Reference
Last update: 14.01.2025
This message is used to update one or several parameters of a sensor during the simulation. [More...](structvss_1_1feedback__control_1_1_feedback_control_description.xhtml#details)
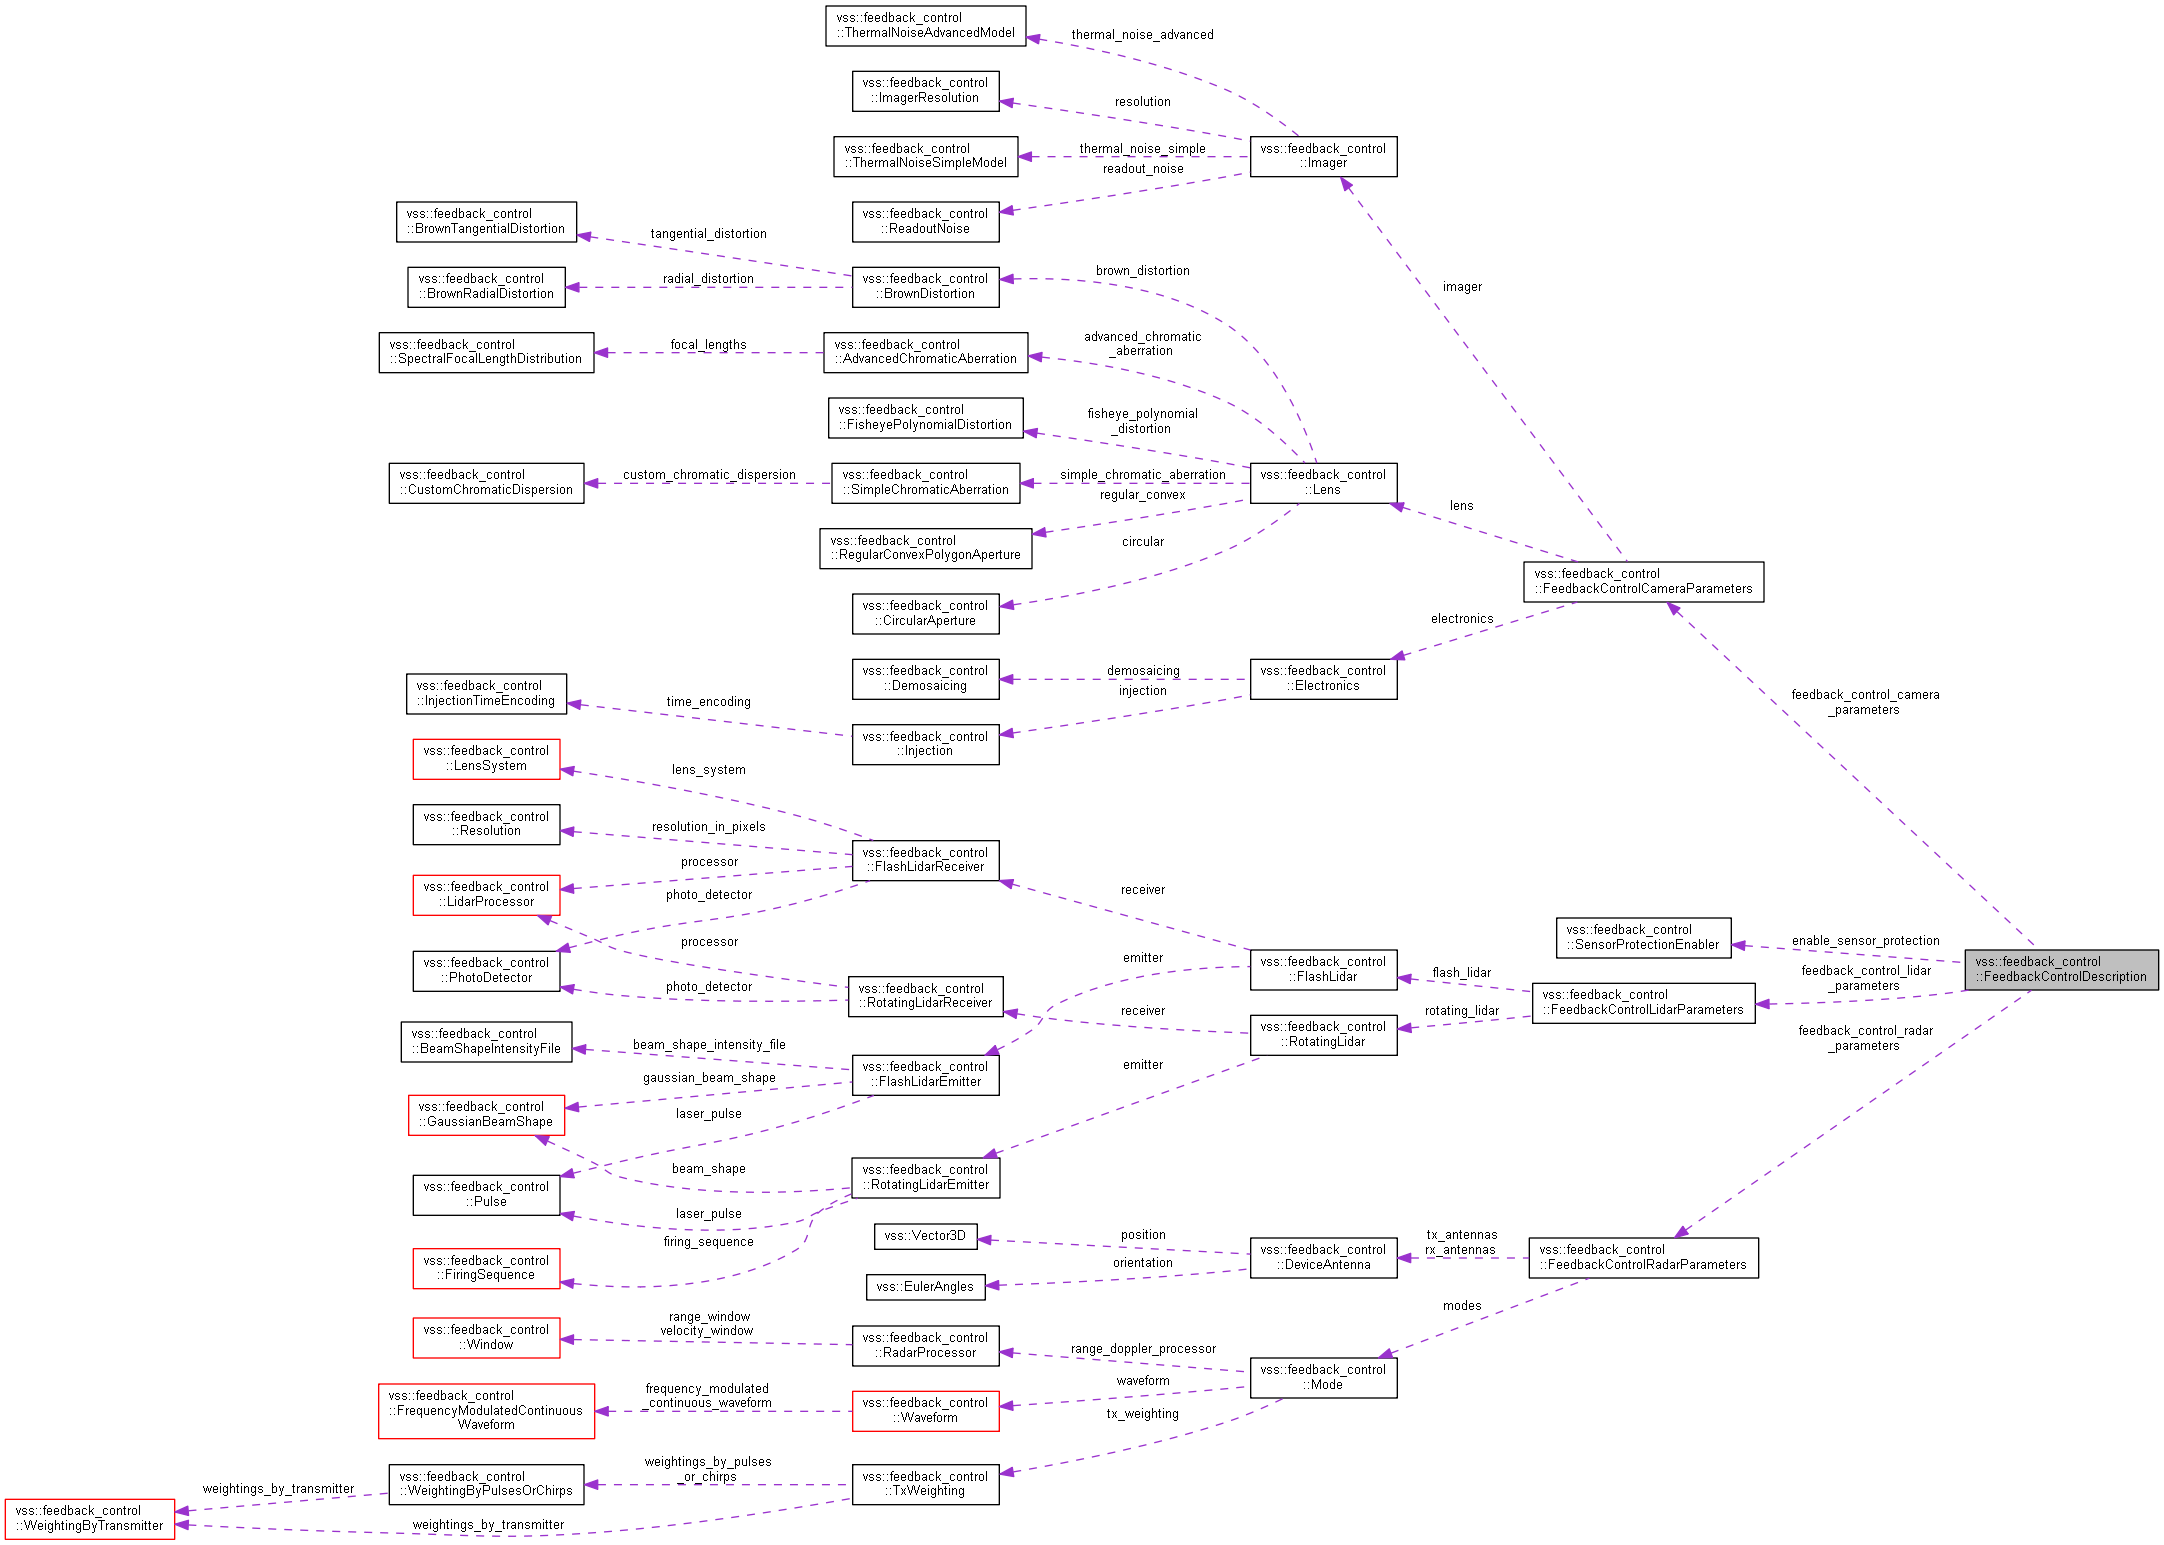
Collaboration diagram for vss::feedback_control::FeedbackControlDescription:
\[[legend](graph_legend.xhtml)\]
## Public Attributes
string [sensor\_id](structvss_1_1feedback__control_1_1_feedback_control_description.xhtml#aa4d921462e30e4d260c3daba6483db70) = 1 [FeedbackControlCameraParameters](structvss_1_1feedback__control_1_1_feedback_control_camera_parameters.xhtml) [feedback\_control\_camera\_parameters](structvss_1_1feedback__control_1_1_feedback_control_description.xhtml#ab5007d80d0512360d9cee713f30843cf) = 2 [FeedbackControlRadarParameters](structvss_1_1feedback__control_1_1_feedback_control_radar_parameters.xhtml) [feedback\_control\_radar\_parameters](structvss_1_1feedback__control_1_1_feedback_control_description.xhtml#a66162939f0aa5a7ee4f0b3c6b544c794) = 3 [FeedbackControlLidarParameters](structvss_1_1feedback__control_1_1_feedback_control_lidar_parameters.xhtml) [feedback\_control\_lidar\_parameters](structvss_1_1feedback__control_1_1_feedback_control_description.xhtml#a699fc07d4f10c51437143379eee788ab) = 4 [SensorProtectionEnabler](structvss_1_1feedback__control_1_1_sensor_protection_enabler.xhtml) [enable\_sensor\_protection](structvss_1_1feedback__control_1_1_feedback_control_description.xhtml#a657072e71c8bd8542719cc7e35e4cced) = 5 ## Detailed Description
This message is used to update one or several parameters of a sensor during the simulation.
Contains the sensor parameters to be updated.
Every time AVX is called with this message, it retrieves the last received values and applies the updates to the sensor model to compute the next output.
NoteAt least one parameter must be provided at each call.
## Member Data Documentation
## [◆ ](#aa4d921462e30e4d260c3daba6483db70)sensor\_id
string vss::feedback\_control::FeedbackControlDescription::sensor\_id = 1
The identifier of the sensor as defined in the sensor configuration.
NoteThis identifier is required for each call and must identify a sensor.
## [◆ ](#ab5007d80d0512360d9cee713f30843cf)feedback\_control\_camera\_parameters
[FeedbackControlCameraParameters](structvss_1_1feedback__control_1_1_feedback_control_camera_parameters.xhtml) vss::feedback\_control::FeedbackControlDescription::feedback\_control\_camera\_parameters = 2
ONEOF(feedback\_control\_sensor\_parameters) This message is used to update a camera parameters during the simulation.
## [◆ ](#a66162939f0aa5a7ee4f0b3c6b544c794)feedback\_control\_radar\_parameters
[FeedbackControlRadarParameters](structvss_1_1feedback__control_1_1_feedback_control_radar_parameters.xhtml) vss::feedback\_control::FeedbackControlDescription::feedback\_control\_radar\_parameters = 3
ONEOF(feedback\_control\_sensor\_parameters) This message is used to update a radar parameters during the simulation.
## [◆ ](#a699fc07d4f10c51437143379eee788ab)feedback\_control\_lidar\_parameters
[FeedbackControlLidarParameters](structvss_1_1feedback__control_1_1_feedback_control_lidar_parameters.xhtml) vss::feedback\_control::FeedbackControlDescription::feedback\_control\_lidar\_parameters = 4
ONEOF(feedback\_control\_sensor\_parameters) This message is used to update a lidar parameters during the simulation.
## [◆ ](#a657072e71c8bd8542719cc7e35e4cced)enable\_sensor\_protection
[SensorProtectionEnabler](structvss_1_1feedback__control_1_1_sensor_protection_enabler.xhtml) vss::feedback\_control::FeedbackControlDescription::enable\_sensor\_protection = 5
Enables IP protection for the sensor. When IP protection is enabled for a radar, no waveform report is generated for this radar. This has no effect on any other sensor.
---
The documentation for this struct was generated from the following file:- feedback\_control\_description.proto