## On this page
# vss::feedback\_control::RadarProcessor Struct Reference
Last update: 14.01.2025
Radar processor parameters. [More...](structvss_1_1feedback__control_1_1_radar_processor.xhtml#details)
Collaboration diagram for vss::feedback_control::RadarProcessor:
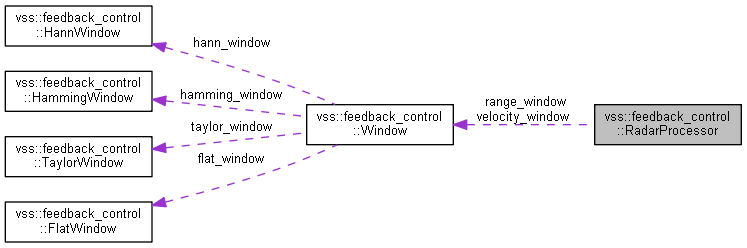
\[[legend](graph_legend.xhtml)\]
## Public Attributes
google::protobuf::Int32Value [range\_pixels](structvss_1_1feedback__control_1_1_radar_processor.xhtml#a9bd9e67f3c5c99a2c6b05502658c8d66) = 1 google::protobuf::Int32Value [velocity\_pixels](structvss_1_1feedback__control_1_1_radar_processor.xhtml#a08a6e2a6812e2fd14734457a2bd90dc1) = 2 [Window](structvss_1_1feedback__control_1_1_window.xhtml) [range\_window](structvss_1_1feedback__control_1_1_radar_processor.xhtml#a3d1d69f1075cf16c846dd5d7ddc134a7) = 3 [Window](structvss_1_1feedback__control_1_1_window.xhtml) [velocity\_window](structvss_1_1feedback__control_1_1_radar_processor.xhtml#a062acef54a6300d3dcfeefb3f76c58fa) = 4 google::protobuf::DoubleValue [center\_velocity](structvss_1_1feedback__control_1_1_radar_processor.xhtml#a2f5374aae6fb9470c2f361d4caf1160a) = 5 ## Detailed Description
Radar processor parameters.
## Member Data Documentation
## [◆ ](#a9bd9e67f3c5c99a2c6b05502658c8d66)range\_pixels
google::protobuf::Int32Value vss::feedback\_control::RadarProcessor::range\_pixels = 1
Range resolution of the output range doppler map image.
## [◆ ](#a08a6e2a6812e2fd14734457a2bd90dc1)velocity\_pixels
google::protobuf::Int32Value vss::feedback\_control::RadarProcessor::velocity\_pixels = 2
Velocity resolution of the output range doppler map image.
## [◆ ](#a3d1d69f1075cf16c846dd5d7ddc134a7)range\_window
[Window](structvss_1_1feedback__control_1_1_window.xhtml) vss::feedback\_control::RadarProcessor::range\_window = 3
Range window of the output range doppler map image.
## [◆ ](#a062acef54a6300d3dcfeefb3f76c58fa)velocity\_window
[Window](structvss_1_1feedback__control_1_1_window.xhtml) vss::feedback\_control::RadarProcessor::velocity\_window = 4
Velocity window of the output range doppler map image.
## [◆ ](#a2f5374aae6fb9470c2f361d4caf1160a)center\_velocity
google::protobuf::DoubleValue vss::feedback\_control::RadarProcessor::center\_velocity = 5
Center value of the velocity range.
---
The documentation for this struct was generated from the following file:- feedback\_control\_radar\_parameters.proto