## On this page
# vss::simulation::KinematicProperties Struct Reference
Last update: 14.01.2025
Properties that define the motion of a solid. [More...](structvss_1_1simulation_1_1_kinematic_properties.xhtml#details)
Collaboration diagram for vss::simulation::KinematicProperties:
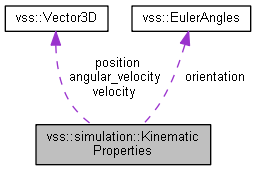
\[[legend](graph_legend.xhtml)\]
## Public Attributes
[Vector3D](structvss_1_1_vector3_d.xhtml) [position](structvss_1_1simulation_1_1_kinematic_properties.xhtml#aefd4109e0a63c370433f58f92e99dc5b) = 1 [Vector3D](structvss_1_1_vector3_d.xhtml) [velocity](structvss_1_1simulation_1_1_kinematic_properties.xhtml#a6dc3fe0d515527feda23777e9413f9c1) = 2 [EulerAngles](structvss_1_1_euler_angles.xhtml) [orientation](structvss_1_1simulation_1_1_kinematic_properties.xhtml#a1e9ee7ba28e92290dcf8613da90e1530) = 3 [Vector3D](structvss_1_1_vector3_d.xhtml) [angular\_velocity](structvss_1_1simulation_1_1_kinematic_properties.xhtml#a64b3cdf985f3bb081388e8119e0360a5) = 4 ## Detailed Description
Properties that define the motion of a solid.
## Member Data Documentation
## [◆ ](#aefd4109e0a63c370433f58f92e99dc5b)position
[Vector3D](structvss_1_1_vector3_d.xhtml) vss::simulation::KinematicProperties::position = 1
Position of the object in the world reference frame.
Unit: meters (m)
## [◆ ](#a6dc3fe0d515527feda23777e9413f9c1)velocity
[Vector3D](structvss_1_1_vector3_d.xhtml) vss::simulation::KinematicProperties::velocity = 2
Velocity of the object relative to the world reference frame.
Unit: meters per second (m/s)
## [◆ ](#a1e9ee7ba28e92290dcf8613da90e1530)orientation
[EulerAngles](structvss_1_1_euler_angles.xhtml) vss::simulation::KinematicProperties::orientation = 3
Orientation of the object relative to the world reference frame.
NoteWhen applying the Euler angles update, it is done in the standard order yaw, pitch, roll.Unit: radians (rad)
## [◆ ](#a64b3cdf985f3bb081388e8119e0360a5)angular\_velocity
[Vector3D](structvss_1_1_vector3_d.xhtml) vss::simulation::KinematicProperties::angular\_velocity = 4
The new angular velocity vector of the object expressed in the world reference frame.
NoteThe value on the Y axis corresponds to the yaw rotation. The value on the X axis corresponds to the pitch rotation. The value on the Z axis corresponds to the roll rotation.Unit: radians per second (rad/s)
---
The documentation for this struct was generated from the following file:- world\_update.proto