## On this page
# vss::simulation::LidarSimulation Struct Reference
Last update: 14.01.2025
Describes simulation parameters for a lidar. [More...](structvss_1_1simulation_1_1_lidar_simulation.xhtml#details)
Collaboration diagram for vss::simulation::LidarSimulation:
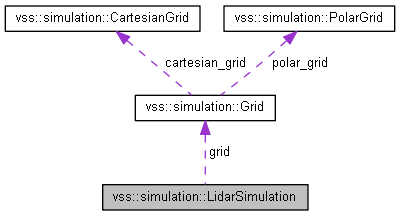
\[[legend](graph_legend.xhtml)\]
## Public Attributes
bool [waveform](structvss_1_1simulation_1_1_lidar_simulation.xhtml#a83c1c68bc4af8352a58e888e57449dd0) = 1 bool [contribution](structvss_1_1simulation_1_1_lidar_simulation.xhtml#af92bd4d6cc507e59da0dffa5bd0249ac) = 2 [Grid](structvss_1_1simulation_1_1_grid.xhtml) [grid](structvss_1_1simulation_1_1_lidar_simulation.xhtml#a83842cf7b7afa4040063c9031a82b17c) = 3 google::protobuf::Int32Value [number\_of\_batches](structvss_1_1simulation_1_1_lidar_simulation.xhtml#af80e7826b0ec5d66d3794cf92311c742) = 4 string [gpu\_name](structvss_1_1simulation_1_1_lidar_simulation.xhtml#a509612d128731b71d5bc3fdd5774d6c8) = 5 bool [use\_rgb\_diffuse](structvss_1_1simulation_1_1_lidar_simulation.xhtml#a08cc1c59ef05209f4d9b2a41ae55bbb4) = 6 ## Detailed Description
Describes simulation parameters for a lidar.
## Member Data Documentation
## [◆ ](#a83c1c68bc4af8352a58e888e57449dd0)waveform
bool vss::simulation::LidarSimulation::waveform = 1
Activation of the waveform output production by the lidar.
Default value: false
## [◆ ](#af92bd4d6cc507e59da0dffa5bd0249ac)contribution
bool vss::simulation::LidarSimulation::contribution = 2
Activation of the contribution output production by the lidar.
Default value: false
## [◆ ](#a83842cf7b7afa4040063c9031a82b17c)grid
[Grid](structvss_1_1simulation_1_1_grid.xhtml) vss::simulation::LidarSimulation::grid = 3
The lidar ray-tracing grid.
## [◆ ](#af80e7826b0ec5d66d3794cf92311c742)number\_of\_batches
google::protobuf::Int32Value vss::simulation::LidarSimulation::number\_of\_batches = 4
The number of batches.
Default value: 1
## [◆ ](#a509612d128731b71d5bc3fdd5774d6c8)gpu\_name
string vss::simulation::LidarSimulation::gpu\_name = 5
The GPU name that must be used for the simulation of this lidar sensor.
NoteThe GPU name must correspond to a [GpuIdentifier](structvss_1_1simulation_1_1_gpu_identifier.xhtml "Represents an identifier for a GPU.") name specified in the deploy parameters.Optional field. If not set, the default GPU (whose index is 0) will be used.
## [◆ ](#a08cc1c59ef05209f4d9b2a41ae55bbb4)use\_rgb\_diffuse
bool vss::simulation::LidarSimulation::use\_rgb\_diffuse = 6
Use RGB diffuse parameters in the simulation of this lidar sensor.
Default value: false
---
The documentation for this struct was generated from the following file:- simulation\_parameters.proto