Spherical stop
Last update: 09.03.2026This example describes the implementation of a spherical stop. A spherical stop is a joint that has 3 rotations (joints include spherical, slot, bushing, free and general joints). This specific type of stop creates a limit to the angle between the z-axis of the reference frame and the z-axis of the moving frame. This functionality is available using the following command:
AddStop(angle_max, restitution_factor)
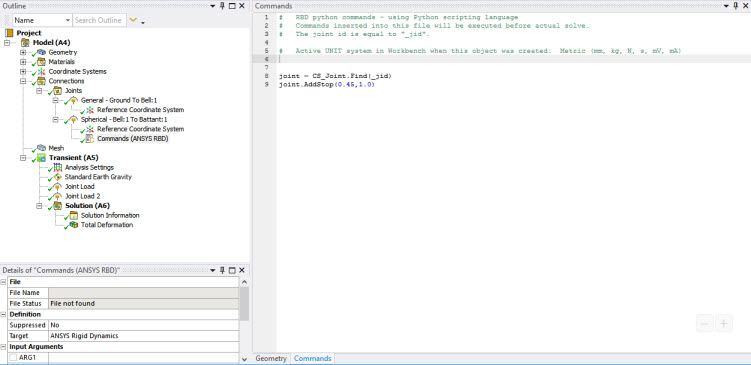
For example, to add a spherical stop for an angle value equal to 0.45 radians and a restitution factor equal to 1.0, the following command would be issued:
Joint.AddStop(0.45,1.0)
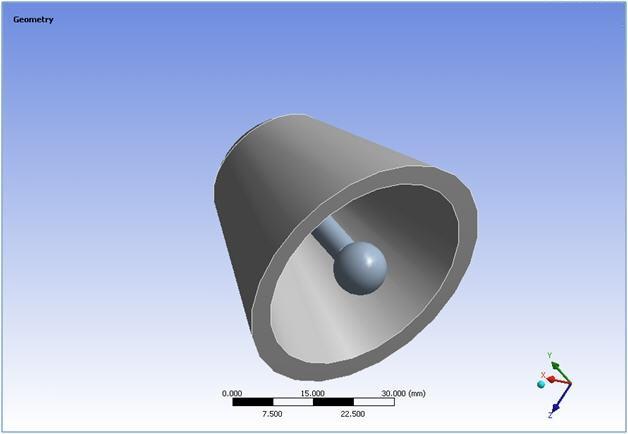
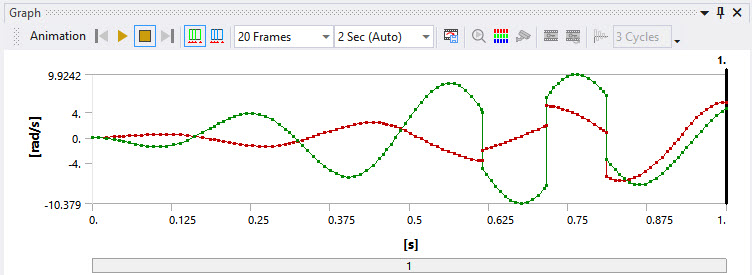
An example of the model and the results of this command are shown below.